Showing posts with label thermal sensors. Show all posts

Saturday, 14 June 2014

Basics of sensors.

In today's post we will be discussing about the working of different types of sensors.
To start with let us discuss the definition of a simple sensor.
  
"A sensor is a converter that measures a physical quantity and converts it into a signal which can be read by an observer or by an (today mostly electronic) instrument."

Its not necessary that a sensor will always be an electronic component. Sensors can be of natural type too. Our body too exhibit different sensing capabilities.

Electronically speaking a sensor is a device, which responds to an input quantity by generating a functionally related output usually in the form of an electrical or optical signal. A sensor's sensitivity indicates how much the sensor's output changes when the measured quantity changes.

The different types of sensors that we use for robotic purposes are:-

1. Infrared sensors
2. Thermal sensors
3. Sound sensors
4. Pressure sensors
5. Ultrasonic sensors etc

For basic purposes like creating grid solvers , obstacle avoiders etc the IR sensors are commonly used . The other named sensors are used for advanced purposes.

Now we will study the working of an IR sensor with its circuitory.         


Working  principle of an IR sensor :

Infra red circuit diagram

A typical system for detecting infrared radiation using infrared sensors includes the infrared source such as blackbody radiators, tungsten lamps, and silicon carbide. In case of active IR sensors, the sources are infrared lasers and LEDs of specific IR wavelengths. Next is the transmission medium used for infrared transmission, which includes vacuum, the atmosphere, and optical fibers.

Thirdly, optical components such as optical lenses made from quartz, CaF2, Ge and Si, polyethylene Fresnel lenses, and Al or Au mirrors, are used to converge or focus infrared radiation. Likewise, to limit spectral response, band-pass filters are ideal.

Finally, the infrared detector completes the system for detecting infrared radiation. The output from the detector is usually very small, and hence pre-amplifiers coupled with circuitry are added to further process the received signals.


There are different types of IR sensors working in various regions of the IR spectrum              but the physics behind "IR sensors" is governed by three laws
:

1.         Planck’s radiation law:

Every object at a temperature T not equal to 0 K emits radiation. Infrared radiant energy is determined by the temperature and surface condition of an object. Human eyes cannot detect differences in infrared energy because they are primarily sensitive to visible light energy from 400 to 700 nm. Our eyes are not sensitive to the infrared energy.
2.         Stephan Boltzmann Law

The total energy emitted at all wavelengths by a black body is related to the absolute temperature as
IR Sensor2
3.         Wein’s Displacement Law

Wein’s Law tells that objects of different temperature emit spectra that peak at different wavelengths. It provides the wavelength for maximum spectral radiant emittance for a given temperature.
The relationship between the true temperature of the black body and its peak spectral exitance or dominant wavelength is described by this law
IR Sensor3The world is not full of black bodies; rather it comprises of selectively radiating bodies like rocks, water, etc. and the relationship between the two is given by emissivity (E).
IR Sensor4Emissivity depends on object color, surface roughness, moisture content, degree of compaction, field of view, viewing angle & wavelength.


ELEMENTS OF INFRARED DETECTION SYSTEM


A typical system for detecting infrared radiation is given in the following block diagram :Elements of IR Detection System
1. Infrared Source: All objects above 0 K radiate infrared energy and hence are infrared sources. Infrared sources also include blackbody radiators, tungsten lamps, silicon carbide, and various others. For active IR sensors, infrared Lasers and LEDs of specific IR wavelengths are used as IR sources. 

2. Transmission Medium: Three main types of transmission medium used for Infrared transmission are vacuum, the atmosphere, and optical fibers.The transmission of IR – radiation is affected by presence of CO2, water vapour and other elements in the atmosphere. Due to absorption by molecules of water carbon dioxide, ozone, etc. the atmosphere highly attenuates most IR wavelengths leaving some important IR windows in the electromagnetic spectrum; these are primarily utilized by thermal imaging/ remote sensing applications.
• Medium wave IR (MWIR:3-5 µm)     •  Long wave IR (LWIR:8-14 µm)IR Sensor5Choice of IR band or a specific wavelength is dictated by the technical requirements of a specific application. 
3. Optical Components: Often optical components are required to converge or focus infrared radiations, to limit spectral response, etc. To converge/focus radiations, optical lenses made of quartz, CaF2, Ge and Si, polyethylene Fresnel lenses, and mirrors made of Al, Au or a similar material are used. For limiting spectral responses, bandpass filters are used. Choppers are used to pass/ interrupt the IR beams. 

4. Infrared detectors: Various types of detectors are used in IR sensors. Important specifications of detectors are:
• Photosensitivity or ResponsivityResponsivity is the Output Voltage/Current per watt of incident energy. Higher the better. 

• Noise Equivalent Power (NEP)NEP represents detection ability of a detector and is the amount of incident light equal to intrinsic noise level of a detector.

• Detectivity(D*: D-star)D* is the photosensitivity per unit area of a detector. It is a measure of S/N ratio of a detector. D* is inversely proportional to NEP. Larger D* indicates better sensing element. In addition, wavelength region or temperature to be measured, response time, cooling mechanism, active area, no of elements, package, linearity, stability, temperature characteristics, etc. are important parameters which need attention while selecting IR detectors.

5.Signal Processing: Since detector outputs are typically very small, preamplifiers with associated circuitry are used to further process the received signals.

Application of IR sensors :-


In robtics the IR sensors are used for various detecting purposes , for e.g to detect nereby objects , in construction of edge avoiders and also in making grid solving intelligent robots.


In our next post we will be discussing about the working of DC geared motors and also the working of the H bridge circuit.

Comments and views will be appreciated.


Thursday, 12 June 2014

The basics of working of a simple robot

We learnt about the different types of robots , their uses and their possible disadvantages as well. Now the important thing is what are the important components of a robot?

As this blog is made for tutorial purposes ,  we will start from the basics and tell you about the components a most basic robot should have.


To start with , let us consider these points :-

A. To work a robot needs an electronic brain which decides what to do and when to do ? for this purpose a robot has a microcontroller. The microcontrollers availaible are of different type and memory sizes. In our tutorials we will be using AVR microcontrollers namely Atmega8/16/32.

B. To get the data from the nearby surrounding , the robot needs to sense them first. Similar to the sensing ability our body has , after the microcontroller the sensors are the most important component.
A robot can have several type of sensors : IR sensors , ultrasonic sensors , thermal sensors , light sensors etc.

C. After the data recieved from the sensors have been processed an output component is required so as the robot does the desired output functions.For this purposes we connect motors etc with the robot. The motors available are of different types namely stepper motor , geared motor , servo motors etc. In case of robots like mechanical hand the output is achieved by use of actuators ( a type of motor itself ).

D. The power source . No doubt if your robot has high grade above mentioned components but the robot is completely useless if it doesnt have a power source.


 Now we will discuss a bit in detail about the several components used :


  • Microcontroller :-


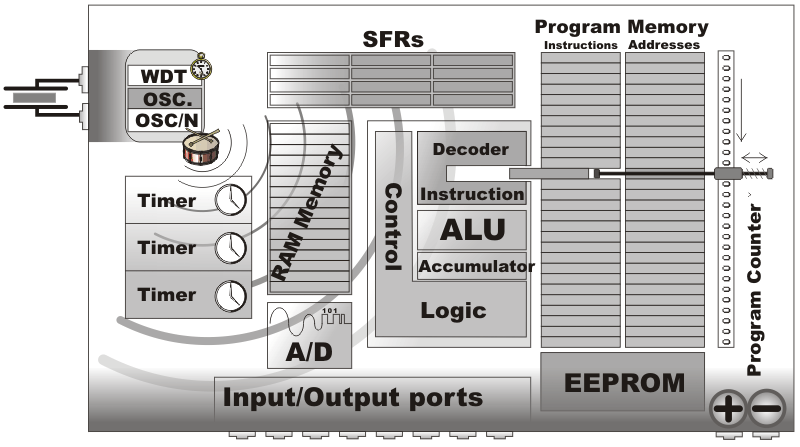
A microcontroller (sometimes abbreviated µC, uC or MCU) is a small computer on a single integrated circuit containing a processor core, memory, and programmable input/output peripherals. Program memory in the form of NOR flash is also often included on chip, as well as a typically small amount of RAM. Microcontrollers are designed for embedded applications, in contrast to the microprocessors used in PCs or other general purpose applications.
Block diagram of Microcontroller

Even though there is a large number of different types of microcontrollers and even more programs created for their use only, all of them have many things in common. Thus, if you learn to handle one of them you will be able to handle them all. A typical scenario on the basis of which it all functions is as follows:

  1. Power supply is turned off and everything is still…the program is loaded into the microcontroller, nothing indicates what is about to come…
  2. Power supply is turned on and everything starts to happen at high speed! The control logic unit keeps everything under control. It disables all other circuits except quartz crystal to operate. While the preparations are in progress, the first milliseconds go by.
  3. Power supply voltage reaches its maximum and oscillator frequency becomes stable. SFRs are being filled with bits reflecting the state of all circuits within the microcontroller. All pins are configured as inputs. The overall electronis starts operation in rhythm with pulse sequence. From now on the time is measured in micro and nanoseconds.
  4. Program Counter is set to zero. Instruction from that address is sent to instruction decoder which recognizes it, after which it is executed with immediate effect.
  5. The value of the Program Counter is incremented by 1 and the whole process is repeated...several million times per second.

  • Sensors :

A sensor is a converter that measures a physical quantity and converts it into a signal which can be read by an observer or by an (today mostly electronic) instrument. For example, a mercury in glass thermometer converts the measured temperature into expansion and contraction of a liquid which can be read on a calibrated glass tube. A  thermocouple converts temperature to an output voltage which can be read by a voltmeter. For accuracy, most sensors are calibrated against known standards.
The different type of sensors availaible to us are: 

1. IR sensors ( Infrared sensors)
2. Thermal sensors
3.Proximity sensors
4. Light sensors
5. Moisture sensors
6. smoke sensors
7. ultrasonic sensors etc.

For the beginner purposes , we will talk only about the IR sensors.

Working Principle

Working of an IR sensor
A typical system for detecting infrared radiation using infrared sensors includes the infrared source such as blackbody radiators, tungsten lamps, and silicon carbide. In case of active IR sensors, the sources are infrared lasers and LEDs of specific IR wavelengths. Next is the transmission medium used for infrared transmission, which includes vacuum, the atmosphere, and optical fibers.

Thirdly, optical components such as optical lenses made from quartz, CaF2, Ge and Si, polyethylene Fresnel lenses, and Al or Au mirrors, are used to converge or focus infrared radiation. Likewise, to limit spectral response, band-pass filters are ideal.

Finally, the infrared detector completes the system for detecting infrared radiation. The output from the detector is usually very small, and hence pre-amplifiers coupled with circuitry are added to further process the received signals.

  • Motors :-
A motor is an electric machine that converts electrical energy into mechanical energy.In robotics several type of motors are used for various purposes.For instance the geared motor is what we commonly use for robot's locomotion.

The 3 main types of motors that are commonly used for robotic purposes are :-


DC geated motor
1. DC geared motors :- Geared DC motors can be defined as an extension of DC motor which already had its . A geared DC Motor has a gear assembly attached to the motor. The speed of motor is counted in terms of rotations of the shaft per minute and is termed as RPM .The gear assembly helps in increasing the torque and reducing the speed. Using the correct combination of gears in a gear motor, its speed can be reduced to any desirable figure. This concept where gears reduce the speed of the vehicle but increase its torque is known as gear reduction.  This Insight will explore all the minor and major details that make the gear head and hence the working of geared DC motor.


2. Stepper motor :- 

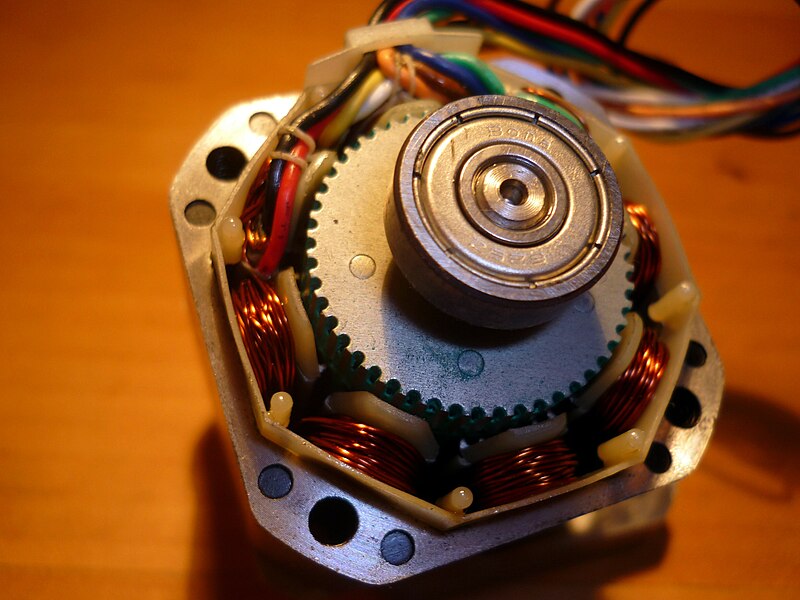
A stepper motor  is a brushless DC electric motor that divides a full rotation into a number of equal steps. The motor's position can then be commanded to move and hold at one of these steps without any feedback sensor (an open loop controller), as long as the motor is carefully sized to the application. DC brushed motors rotate continuously when voltage is applied to their terminals.


Stepper motor
The stepper motor is known by its important property to convert a train of input pulses (typically square wave pulses) into a precisely defined increment in the shaft position. Each pulse moves the shaft through a fixed angle. Stepper motors effectively have multiple "toothed" electromagnets arranged around a central gear-shaped piece of iron. The electromagnets are energized by an external control circuit, such as a microcontroller. To make the motor shaft turn, first, one electromagnet is given power, which magnetically attracts the gear's teeth. When the gear's teeth are aligned to the first electromagnet, they are slightly offset from the next electromagnet. So when the next electromagnet is turned on and the first is turned off, the gear rotates slightly to align with the next one, and from there the process is repeated. Each of those rotations is called a "step", with an integer number of steps making a full rotation. In that way, the motor can be turned by a precise angle.

Servo motor

3. Servomotor : A servomotor is a rotor actuator that allows for precise control of angular position, velocity and acceleration. It consists of a suitable motor coupled to a sensor for position feedback. It also requires a relatively sophisticated controller, often a dedicated module designed specifically for use with servomotors.

Servomotors are not a specific class of motor although the term servomotor is often used to refer to a motor suitable for use in a closed-loop control system.


In our next post we will be discussing in detail about the microcontrollers , their types and their architectures.


Comments and views will be appreciated.